Remote human-robot interaction

RI

Description

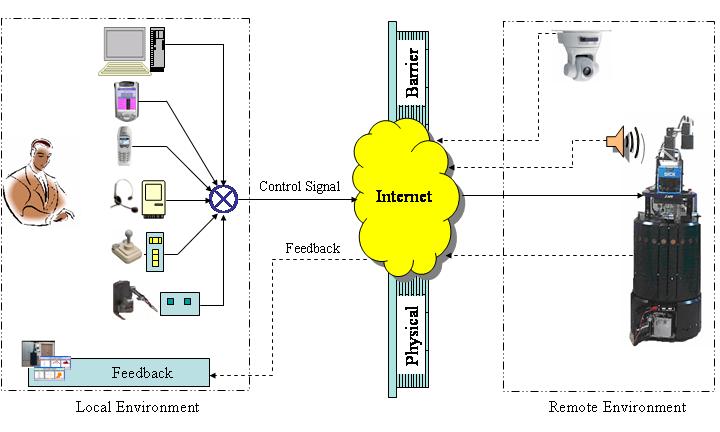
Regardless of the application, most of the remote interaction systems consist of the following basic components:

– An operator interface, incorporating an interaction device that the operator uses to send control commands to the remote system. There are many types of interaction devices such as PCs, mobile devices such as Personal Digital Assistants (PDA) and mobile phones, speech-based communication, joysticks and haptic interfaces.

– A mobile robot that performs the operator?s commanded actions at the remote site.

– A communication scheme between sites. It is recommended that the communication scheme have a robust signal communication link with an acceptable time delay; dedicated data links with sufficient throughput; and an effective data loss-recovery approach. As mentioned previously, although Internet is a cheap, readily accessible communication medium, its performance has nondeterministic characteristics.

– Feedback interfaces. Video transmission is commonly used to provide visual feedback for the operator. Video transmission demands high bandwidth availability. When this is not possible, computer-generated imagery supplies the operator with a virtual interface that combines low bandwidth sensory data to form a realistic image. These virtual interfaces are also useful to overlaying computer predictions or visual clues onto video images. Auditory feedback can also be used to enhance visual experience and human robot interaction. Although audio transmission requires low bandwidth, it is very sensitive to time delay and jitter. Other type of feedback can be provided using kinesthetic aids. Using haptic systems the operator can sense the response of its commands directly in the control interface.

Remote interaction systems can be used in many useful applications such as remote experimentation, teleoperation, teleperception, teleprogramming, etc.

Remote laboratories can be considered innovative environments, which can be used to provide remote interaction with mobile robots for educational and research purposes. They can be defined as network-based laboratories where the user and the real laboratory equipment are geographically separated and where telecommunication technologies are used to give users access to laboratory equipment. Such laboratories have the advantage that they are not restricted to synchronized attendance by instructors and students: thus they have the potential to provide constant access whenever needed by students.

In recent years, many researchers have built remote laboratories for mobile robots using similar architectures and implementation tools. Many such remote facilities can be put together to form a framework or a distributed laboratory that can be used to provide a coordinated set of experiments for students with hardware facilities physically spread over different locations, but accessible via the Internet. The project IECAT (Innovative Educational Concepts for Autonomous and Teleoperated Systems) in which RoboticsLab has participated is an example of such frameworks in the field of mechatronics. Such frameworks is an electronic workspace for distance collaboration and experimentation in research or in another creative activity, to generate and deliver results using distributed information and communication technologies. They assist in the exchange of existing hardware resources and educational materials between the partners.

Entries:
A new approach to modelling emotions and their use on a decision making system for artificial agent
IEEE Transactions on Affective Computing . num. 1 , vol. 3 , pages: 56 – 68 , 2012
M. Malfaz M.A. Salichs
Tracking moving optima using Kalman-based predictions
Evolutionary Computation (ISSN: 1063-6560). num. 1 , vol. 16 , pages: 1 – 38 , 2008
J.C. Diaz M. Abderrahim
Pose Estimation for Variable Configuration Objects:an Evolutionary Approach to Vision-based Navigation and Inspection
WSEAS Transactions on Information Science & Applications. num. 3 , vol. 3 , pages: 538 – 545 , 2006
J.C. Diaz M. Abderrahim
Visual Approach Skill for a Mobile Robot using Learning and Fusion of Simple Skills
Robotics and Autonomous Systems. num. 3 , vol. 38 , pages: 157 – 170 , 2002
R. Barber M.A. Salichs

Entries:
Mechatronics Testbed for Vision based Navigation
9th Mechatronics Forum International Conference (Mechatronics2004), 2004, Ankara, Turkey
J.C. Diaz M. Abderrahim M.A. Salichs
An Evolutionary Algorithm for Model-Based Pose Estimation and Tracking
The International Conference on Visual Information Engineering (VIE 2005), 2005, Glasgow, UK
J.C. Diaz M. Abderrahim
Traffic Sign Recognition for Autonomous Vehicles
International symposium on Advanced Transportation Applications, 1994, Aachen, Germany
L. Moreno M.A. Salichs
A control System Based on Reactive Skills for Autonomous Mobile Robots
The 11th International Conference on Advanced Robotics, 2003, Coimbra, Portugal
R. Barber M.A. Salichs
A Perception System based on Laser Information for Mobile Robot Topologic Navigation
IEEE Int. Conference on Industrial Electronics, Control and Instrumentation, 2002, Sevilla, Spain
R. Barber M.A. Salichs
Visual Tracking Skill Reinforcement Learning for a Mobile Robot
IFAC Symposium on Intelligent Autonomous Vehicles, 2002, Sapporo, Japan
M.A. Salichs
Detección y Clasificación de señales de tráfico mediante redes neuronales
4º Congreso de la Asociación Española de Robótica, Zaragoza, Spain
L. Moreno M.A. Salichs
Percepción de Carreteras y Detección de Señales de Tráfico
XVI Jornadas de Automática, 1995, San Sebastian, Spain
L. Moreno M.A. Salichs
Adaptive control of a DC motor for educational practices
ACE2013 The 10th IFAC Symposium on Advances in Control Education , 2013, Sheffield, UK
S. Garrido R. Barber
Object Reconstruction and Recognition leveraging an RGB-D camera.
In proceedings Twelfth IAPR Conference on Machine Vision Applications, -,
N. Burrus J.G. Bueno M. Abderrahim L. Moreno
Assistive robots dependability in domestic environment: the ASIBOT kitchen test bed
IARP-IEEE/RAS-EURON Joint Workshop on Shared Control for Robotic Ultra-operations, San Diego, California, Oct 28-30, 2007, 2007, San Diego, CA, EEUU
A. Gimenez S. Martinez A. Jardon
Modified SoftPOSIT algorithm for 3D visual tracking
2007 IEEE International Symposium on Intelligent Signal Processing (WISP'2007), 2007, Alcala Henares, Spain
J.C. Diaz M. Abderrahim
Visual Inspection System for Autonomous Robotic On-Orbit Satellite Servicing
ASTRA2006: 9th ESA Workshop on Advanced Space Technologies for Robotics and Automation, 2006, Noordwijk, The Netherlands
J.C. Diaz M. Abderrahim
Automated Visual Inspection for Robotic On-Orbit Servicing
MX2006: The 10th Mechatronics Forum Biennial International Conference, 2006, Malvern, Pennsy, USA
J.C. Diaz M. Abderrahim
Evolutionary Model-Based Pose Estimation for Variable Configuration Objects
ISPRA 2006: 5th WSEAS International Conference on Signal Processing, Robotics and Automation, 2006, Alcala Henares, Spain
J.C. Diaz M. Abderrahim
Satellite Relative Navigation Based on Visual Feedback
i-SAIRAS2005: 8th International Symposium on Artificial Intelligence, Robotics and Automation in Space, 2005, Münich, Germany
J.C. Diaz M. Abderrahim M.A. Salichs
EvoPose: A Model-based Pose Estimation Algorithmwith Correspondences Determination
IEEE InternationalConference on Mechatronics and Automation (ICMA 2005), 2005, Niagara Falls,, Canada
J.C. Diaz M. Abderrahim
Experimental Simulation of Satellite Relative Navigation using Computer Vision
RAST2005: 2nd International Conference on Recent Advances in Space Technologies, 2005, Istanbul, Turkey
J.C. Diaz M. Abderrahim M.A. Salichs

Entries:
Grasping in Robotics
chapter: A survey on different control techniques for grasping pages: 223 – 246. SPRINGER NETHERLANDS EDITORIAL , ISBN: 978-3-540-71363, 2013
R. Cabas A. Gimenez S. Martinez A. Jardon
Seguimiento e identificación de objetos
chapter: Estimación de la posición y la orientación de objetos 3D basado en modelación geométrica pages: 1 – 8. A. Grau, A. Sanfeliu et al. (UPC, Servicio de Publicaciones) , ISBN: 84-7653-849-9, 2004
J.C. Diaz M. Abderrahim M.A. Salichs

Previous Research topics

next Research topics