Assistive portable robots design

42_G

Description

Today, health care has become one of the very potential businesses. The world population is becoming old, and many people are highly concerned about their welfare. It is very important to give a thoughtful consideration to the handicapped and the elderly. Nevertheless, the research about helping those people are currently limited to the enhancement of residential or welfare equipment such as the wheelchair, intelligent bed, assistance robot system for the handicapped, etc. Therefore, it is necessary to help the handicapped and the elderly to be a more productive member of the society in addition to being independent of care-givers.
Further, it will help them to live not as burdens to the society but with self-confidence as those who can contribute to the society. 
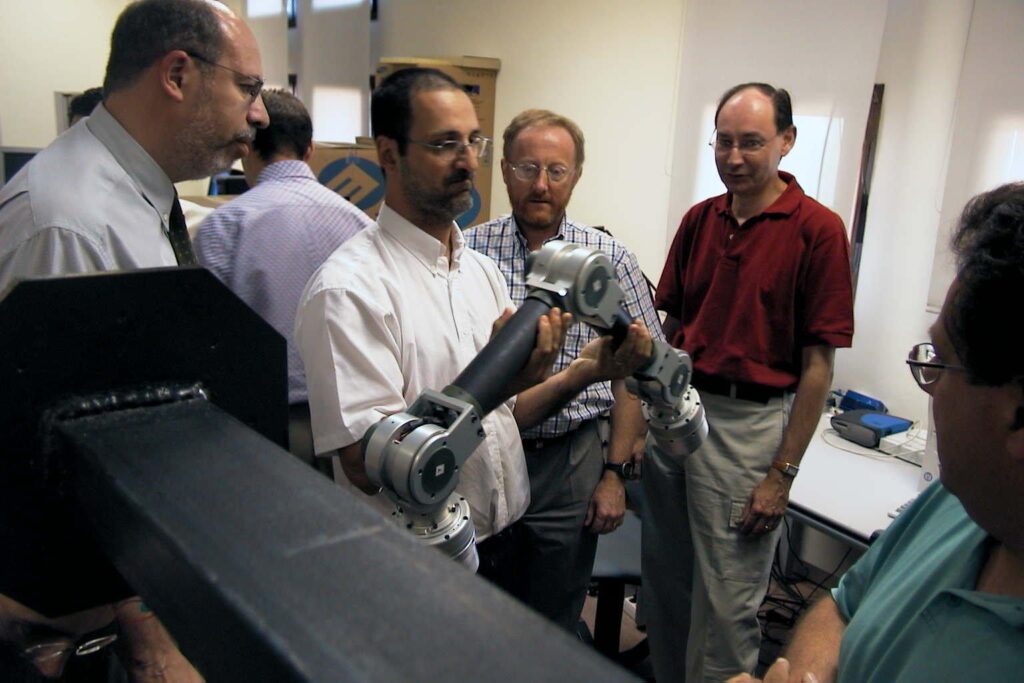
The main goal of this research area is to design and develop really portable assistive robotic devices able to be transported easily by the user in his daily trip from house to office, providing the assistance in both environments. 
In this way it’s possible to dock the MATS to the wheelchair, and once in the office undock automatically the robot and start to use in the adapted office environment.

Entries:
Remote Interaction with Mobile Robots
Autonomous Robots. num. 3 , vol. 15 , pages: 267 – 281 , 2003
A.M. Khamis M.A. Salichs
Software Architecture for Internet Mobile Robotics
Robotics and Machine Perception. SPIE. num. 1 , vol. 12 , pages: 7 – 11 , 2003
A.M. Khamis M.A. Salichs

Entries:
Humanoid Teleoperation System for Space Environments
14th International Conference on Advanced Robotics (ICAR '09), 2009, Munich, Germany
P. Pierro M. González-Fierro D. Hernandez
Maggie: A Robotic Platform for Human-Robot Social Interaction
IEEE International Conference on Robotics, Automation and Mechatronics (RAM 2006), 2006, Bangkok, Thailand
E. Delgado A. Corrales R. Rivas R. Pacheco A.M. Khamis Javi F. Gorostiza M. Malfaz R. Barber M.A. Salichs
Sistema de Interacción Remota con Robots Móviles basado en Internet I
I Jornadas de Trabajo: Educación en Automática. DocenWeb: Red Temática de Docencia en Control mediante Web, 2004, Alicante, Spain
A.M. Khamis R. Barber M.A. Salichs
Pattern-based Architecture for Building Mobile Robotics Remote Laboratories
IEEE International Conference on Robotics and Automation, Taipei, Taiwan
M. Rivero A.M. Khamis M.A. Salichs
Multiact Approach for Building Web-based Educational Environments: Mobile Robotics Course as a Case Study
The 11th Mediterranean Conference on Control and Automation, MED'03, Rhodes, Greece
A.M. Khamis M.A. Salichs
The Merging to eLearning in Mobile Robotics
15th IFAC World Congress on Automatic Control (b?02), Barcelona, Spain
A.M. Khamis M.A. Salichs
Laboratorio a Distancia via Internet en Robotica Móvil
III Jornada de Trabajo – Enseñanza Vía Internet/Web de la Ingeniería de Sistemas y Automática- EIWSA 2002, 2004, Alicante, Spain
A.M. Khamis M.A. Salichs
Design of a Remote Laboratory on Mobile Robots
Internet-based Control Eduaction, IBCE01, Madrid, Spain
A.M. Khamis M.A. Salichs
A Remote Laboratory for Teaching Mobile Robotics
IFAC Conference on Telematics Applications and Robotics (TA2001), 2001, Weingarten, Germany
A.M. Khamis M.A. Salichs
Teaching Mobile Robotics to Anyone, Anywhere at Anytime
1st. EURON Workshop on Robotics Education and Training RET 2001, 2001, Weingarten, Germany
A.M. Khamis M.A. Salichs
Sensorial Data Acquisition Process for a Mobile Robot in the Virtual Laboratory
International Workshop in Teleeducation in Mechatronics based on Virtual Laboratories, 2001, Weingarten, Germany
A.M. Khamis M.A. Salichs

Previous Research topics

next Research topics