Humanoid head design

Clip

Description


This research line forms a part of a bigger project, the Rh-1


This research line
forms a part of a bigger project, the Rh-1. Rh-1 is a humanoid robot that will
be able to automomously walk and interact with persons. The head is in the
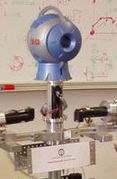
development phase and we are using a dummy toy head as a substitute in the
photos.


When we are saying
"head" we do not necessarily mean that everything will be put in the
head. We are speaking about the sensory system of the robot in general. The
head itself will contain a network camera and an array of microphones, and the
CPU to process all the data will be located in the body of the robot. There
will also be some other sensors that may probably include a laser distance
meter, gyroscopes and accelerometers. We are currently researching in this
field.


Right now there are
several jobs being done: the development of algorithms to process images from
the camera, the development of the DSP card for the microphones, the
development of a voice recognition system as well as some other work.


Thank you for your
interest.


If you have any
question or suggestion concerning this project, please don’t hesistate in
contacting us.


E-mail:
pstarove*ing.uc3m.es (put @ instead of *)

Entries:
Usability assessment of ASIBOT: a portable robot to aid patients with spinal cord injury
Disability & Rehabilitation: Assistive Technology. , pages: 1 – 11 , 2010
A. Jardon C.A. Monje A. Gil A. Peña
The MATS robot: Service Climbing Robot for Personal Assistance
IEEE Robotics & Automation Magazine. num. 1 , vol. 13 , pages: 51 – 58 , 2006
A. Gimenez A. Jardon
Robots applications against gravity
IEEE Robotics & Automation magazine. num. 1 , vol. 13 , pages: 5 – 6 , 2006

Entries:
Benchmarking Shared Control for Assistive Manipulators: From Controllability to the Speed-Accuracy Trade-Off
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2012), 2012, Vilamoura, Portugal
M.F. Stoelen F. Bonsignorio A. Jardon
Experimental evaluation of assistive robots in virtual domestic scenarios
International Symposium for Automation and Robotics in Construction (ISARC/Gerontechnology 2012). Vol. 11. Num. 2, 2012, Eindhoven, The Netherlands
A. Jardon Juan G. Victores M.F. Stoelen S. Martinez
Methodologies for Experimental Evaluation of Assistive Robotics HRI
ROBOCITY2030 9TH WORKSHOP: ROBOTS COLABORATIVOS E INTERACCION HUMANO-ROBOT, 2011, Madrid, Spain
M.F. Stoelen A. Jardon V. Tejada Juan G. Victores S. Martinez F. Bonsignorio
An information-theoretic approach to modeling and quantifying assistive robotics HRI
Late Breaking Report, Proceedings of the 6th international conference on Human-robot interaction (HRI), Lausanne, Switzerland
M.F. Stoelen F. Bonsignorio A. Jardon
Assistive robots dependability in domestic environment: the ASIBOT kitchen test bed
IARP-IEEE/RAS-EURON Joint Workshop on Shared Control for Robotic Ultra-operations, San Diego, California, Oct 28-30, 2007, 2007, San Diego, CA, EEUU
A. Gimenez S. Martinez A. Jardon
A. I. de la Peña González, A. M. Gil Agudo, Functional Evaluation of ASIBOT, a Portable Robot to Aid Disabled Persons
In Proceedings II International Congress on Domotics, Robotics and Remote‐Assistance for All DRT4all 2007, 2007, Madrid, SPAIN
A. Jardon
Live experimentation of the service robot applicationselderly people care in home environments
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS'2005), Edmonton, Canada
R. Cabas R. Correal A. Gimenez A. Jardon
Wireless Teleoperation of an Assistive Robot by PDA
The 1st IFAC Symposium on Telematics Applications In Automation and Robotics, 2004, Helsinki, Finland
R. Correal A. Gimenez A. Jardon

Entries:
Progress in Robotics. Communications in Computer and Information Science 44
chapter: Infrared Remote Control with a Social Robot pages: 86 – 95. Springer , ISBN: 978-3-642-03985, 2009
A. Castro-Gonzalez M.A. Salichs
M. Ferre, M. Buss, C. Melchiorri. Advances in Telerobotics
chapter: Introduction to Advances in Telerobotics pages: 1 – 10. Springer Tracts in Advanced Robotics (STAR), vol. 31 , ISBN: 978-3-540-71363, 2007

Previous Research topics

next Research topics