Grasping / Learning

grasping1

Description

Nowadays, image treatment is one of the biggest barriers in robotics. Some aspects that are simply a priori for individuals (like object discrimination), are not so obvious when treating them using computers.

The problem arises when associating points belonging to the same object. Our brain does this process automatically, but it is not so clear when we try to do it digitally. The machine cannot identify the environment as a set of elements but as a set of unrelated pixels.

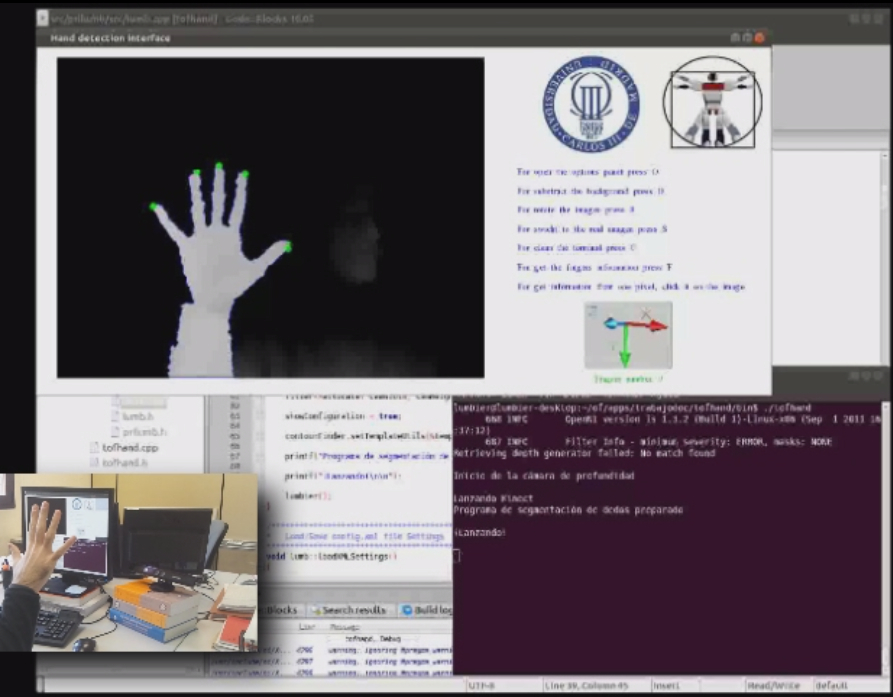
Following this line of argument, we want to design algorithm that find/identify/recognize the human hand and segmentate it. Once the segmentation is done, we discriminate among its physiological elements (palm and fingers), and the hand can be represented graphically in real-time when gesturing.

The final goal is to teach the robot to manipulate objects without human interaction.

Entries:
Usability assessment of ASIBOT: a portable robot to aid patients with spinal cord injury
Disability & Rehabilitation: Assistive Technology. , pages: 1 – 11 , 2010
A. Jardon C.A. Monje A. Gil A. Peña
The MATS robot: Service Climbing Robot for Personal Assistance
IEEE Robotics & Automation Magazine. num. 1 , vol. 13 , pages: 51 – 58 , 2006
A. Gimenez A. Jardon
Robots applications against gravity
IEEE Robotics & Automation magazine. num. 1 , vol. 13 , pages: 5 – 6 , 2006

Entries:
Benchmarking Shared Control for Assistive Manipulators: From Controllability to the Speed-Accuracy Trade-Off
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2012), 2012, Vilamoura, Portugal
M.F. Stoelen F. Bonsignorio A. Jardon
Experimental evaluation of assistive robots in virtual domestic scenarios
International Symposium for Automation and Robotics in Construction (ISARC/Gerontechnology 2012). Vol. 11. Num. 2, 2012, Eindhoven, The Netherlands
A. Jardon Juan G. Victores M.F. Stoelen S. Martinez
Methodologies for Experimental Evaluation of Assistive Robotics HRI
ROBOCITY2030 9TH WORKSHOP: ROBOTS COLABORATIVOS E INTERACCION HUMANO-ROBOT, 2011, Madrid, Spain
M.F. Stoelen A. Jardon V. Tejada Juan G. Victores S. Martinez F. Bonsignorio
An information-theoretic approach to modeling and quantifying assistive robotics HRI
Late Breaking Report, Proceedings of the 6th international conference on Human-robot interaction (HRI), Lausanne, Switzerland
M.F. Stoelen F. Bonsignorio A. Jardon
Assistive robots dependability in domestic environment: the ASIBOT kitchen test bed
IARP-IEEE/RAS-EURON Joint Workshop on Shared Control for Robotic Ultra-operations, San Diego, California, Oct 28-30, 2007, 2007, San Diego, CA, EEUU
A. Gimenez S. Martinez A. Jardon
A. I. de la Peña González, A. M. Gil Agudo, Functional Evaluation of ASIBOT, a Portable Robot to Aid Disabled Persons
In Proceedings II International Congress on Domotics, Robotics and Remote‐Assistance for All DRT4all 2007, 2007, Madrid, SPAIN
A. Jardon
Live experimentation of the service robot applicationselderly people care in home environments
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS'2005), Edmonton, Canada
R. Cabas R. Correal A. Gimenez A. Jardon
Wireless Teleoperation of an Assistive Robot by PDA
The 1st IFAC Symposium on Telematics Applications In Automation and Robotics, 2004, Helsinki, Finland
R. Correal A. Gimenez A. Jardon

Entries:
Progress in Robotics. Communications in Computer and Information Science 44
chapter: Infrared Remote Control with a Social Robot pages: 86 – 95. Springer , ISBN: 978-3-642-03985, 2009
A. Castro-Gonzalez M.A. Salichs
M. Ferre, M. Buss, C. Melchiorri. Advances in Telerobotics
chapter: Introduction to Advances in Telerobotics pages: 1 – 10. Springer Tracts in Advanced Robotics (STAR), vol. 31 , ISBN: 978-3-540-71363, 2007

Previous Research topics

next Research topics