COMANDER

Safe and multimodal cooperation with robotic assistants for people with special needs

Main researcher: A. Jardon

comander_logo

Description

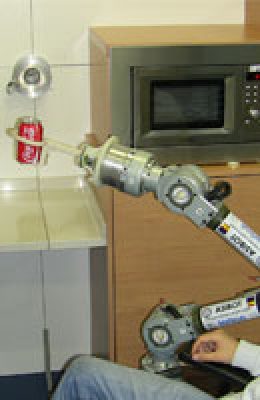
For the development of usable assistive robots for elderly and disabled an important part is to allow for multimodal Human-Robot Interaction (HRI). However, the overall human-machine system is complex. The user and the robot are operating in a closed loop and both are potentially capable of adapting to the other. The work presented here has attempted to approach the problem from three different perspectives, investigating methods for analyzing, implementing, and testing an enabling multimodal interface for the ASIBOT. The main purpose of multimodality is then here to reduce control inaccurate interpretation of user intentions. A reliable human centered SW architecture allows high level commands from the different modalities. That is, the user will simultaneously coordinate different modalities so as to make his/her intention clearer to the system. Safety and dependability will be the underlying evaluation criteria for new mechanical designs, actuation, and control architectures to deliver performance.
Entries:

Entries:
Robotic Arm Platform Development for Educational Purposes
14th annual International Conference of Education, Research and Innovation, 2021, Online,
R. Barber R. Sánchez A. Mora
Teaching Robot Planners Using a Practical Approach
15th International Technology, Education and Development , 2021, Online,
A. Mora R. Sánchez R. Barber
Object-based Pose Graph for Dynamic Indoor Environments
2020 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Las Vegas, USA
C. Gómez A. C. Hernández R. Barber E. Derner R. Babuska
Efficient Object Search Through Probability-Based Viewpoint Selection
2020 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Las Vegas, USA
A. C. Hernández C. Gómez R. Barber E. Dernier R. Babuska
Course Content for Learning GPU
13th annual International Conference of Education, Research and Innovation, Sevilla, SPAIN
G. Camporredondo R. Barber L. Muñoz M. Legrand
Indoor Scene Recognition based on Weighted Voting Schemes.
European Conference on Mobile Robots (ECMR)., Prague,, Czech Republic
A. C. Hernández C. Gómez R. Barber
Learning How Path Planning Algorithms Work
16th International Technology, Education and Development Conference, 2022, Online Conference,
A. Prados A. Mora R. Barber
Segmenting Maps by Analyzing Free and Occupied Regions with Voronoi Diagrams
International Conference on Informatics in Control, Automation and Robotics (ICINCO),, 2022, Lisboa, Portugal
A. Mora A. Prados R. Barber
Robotic Arm Platform Development for Educational Purposes
14th annual International Conference of Education, Research and Innovation, 2021, Online,
R. Barber R. Sánchez A. Mora
Teaching Robot Planners Using a Practical Approach
15th International Technology, Education and Development , 2021, Online,
A. Mora R. Sánchez R. Barber
Object-based Pose Graph for Dynamic Indoor Environments
2020 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Las Vegas, USA
C. Gómez A. C. Hernández R. Barber E. Derner R. Babuska
Efficient Object Search Through Probability-Based Viewpoint Selection
2020 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Las Vegas, USA
A. C. Hernández C. Gómez R. Barber E. Dernier R. Babuska
Course Content for Learning GPU
13th annual International Conference of Education, Research and Innovation, Sevilla, SPAIN
G. Camporredondo R. Barber L. Muñoz M. Legrand
Indoor Scene Recognition based on Weighted Voting Schemes.
European Conference on Mobile Robots (ECMR)., Prague,, Czech Republic
A. C. Hernández C. Gómez R. Barber
Learning How Path Planning Algorithms Work
16th International Technology, Education and Development Conference, 2022, Online Conference,
A. Prados A. Mora R. Barber
Segmenting Maps by Analyzing Free and Occupied Regions with Voronoi Diagrams
International Conference on Informatics in Control, Automation and Robotics (ICINCO),, 2022, Lisboa, Portugal
A. Mora A. Prados R. Barber
Robotic Arm Platform Development for Educational Purposes
14th annual International Conference of Education, Research and Innovation, 2021, Online,
R. Barber R. Sánchez A. Mora
Teaching Robot Planners Using a Practical Approach
15th International Technology, Education and Development , 2021, Online,
A. Mora R. Sánchez R. Barber
Object-based Pose Graph for Dynamic Indoor Environments
2020 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Las Vegas, USA
C. Gómez A. C. Hernández R. Barber E. Derner R. Babuska
Efficient Object Search Through Probability-Based Viewpoint Selection
2020 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Las Vegas, USA
A. C. Hernández C. Gómez R. Barber E. Dernier R. Babuska
Course Content for Learning GPU
13th annual International Conference of Education, Research and Innovation, Sevilla, SPAIN
G. Camporredondo R. Barber L. Muñoz M. Legrand
Indoor Scene Recognition based on Weighted Voting Schemes.
European Conference on Mobile Robots (ECMR)., Prague,, Czech Republic
A. C. Hernández C. Gómez R. Barber
Learning How Path Planning Algorithms Work
16th International Technology, Education and Development Conference, 2022, Online Conference,
A. Prados A. Mora R. Barber
Segmenting Maps by Analyzing Free and Occupied Regions with Voronoi Diagrams
International Conference on Informatics in Control, Automation and Robotics (ICINCO),, 2022, Lisboa, Portugal
A. Mora A. Prados R. Barber
Robotic Arm Platform Development for Educational Purposes
14th annual International Conference of Education, Research and Innovation, 2021, Online,
R. Barber R. Sánchez A. Mora
Teaching Robot Planners Using a Practical Approach
15th International Technology, Education and Development , 2021, Online,
A. Mora R. Sánchez R. Barber
Object-based Pose Graph for Dynamic Indoor Environments
2020 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Las Vegas, USA
C. Gómez A. C. Hernández R. Barber E. Derner R. Babuska
Efficient Object Search Through Probability-Based Viewpoint Selection
2020 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Las Vegas, USA
A. C. Hernández C. Gómez R. Barber E. Dernier R. Babuska
Course Content for Learning GPU
13th annual International Conference of Education, Research and Innovation, Sevilla, SPAIN
G. Camporredondo R. Barber L. Muñoz M. Legrand
Indoor Scene Recognition based on Weighted Voting Schemes.
European Conference on Mobile Robots (ECMR)., Prague,, Czech Republic
A. C. Hernández C. Gómez R. Barber
Learning How Path Planning Algorithms Work
16th International Technology, Education and Development Conference, 2022, Online Conference,
A. Prados A. Mora R. Barber
Segmenting Maps by Analyzing Free and Occupied Regions with Voronoi Diagrams
International Conference on Informatics in Control, Automation and Robotics (ICINCO),, 2022, Lisboa, Portugal
A. Mora A. Prados R. Barber

Previous Project

next project