ALMA

Human Centric Algebraic Machine Learning

Main researcher: A. Jardon

ALMA

Description

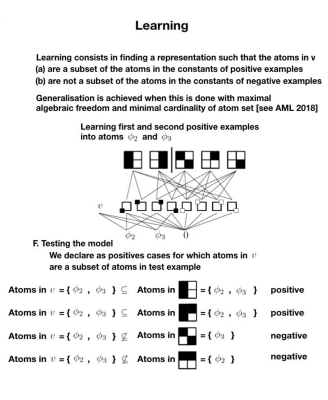
Algebraic Machine Learning (AML) has recently been proposed as new learning paradigm that builds upon Abstract Algebra, Model Theory. Unlike other popular learning algorithms, AML is not a statistical method, but it produces generalizing models from semantic embeddings of data into discrete algebraic structures, with the following properties:
  • P1: Is far less sensitive to the statistical characteristics of the training data and does not fit (or even use) parameters
  • P2: Has the potential to seamlessly integrate unstructured and complex information contained in training data, with a formal representation of human knowledge and requirements;
  • P3. Uses internal representations based on discrete sets and graphs, offering a good starting point for generating human understandable, descriptions of what, why and how has been learned
  • P4. Can be implemented in a distributed way that avoids centralized, privacy-invasive collections of large data sets in favor of a collaboration of many local learners at the level of learned partial representations.

The aim of the project is to leverage the above properties of AML for a new generation of Interactive, Human-Centric Machine Learning systems., that will:
  • Reduce bias and prevent discrimination by reducing dependence on statistical properties of training data (P1), integrating human knowledge with constraints (P2), and exploring the how and why of the learning process (P3)
  • Facilitate trust and reliability by respecting ‘hard’ human-defined constraints in the learning process (P2) and enhancing explainability of the learning process (P3)
  • Integrate complex ethical constraints into Human-AI systems by going beyond basic bias and discrimination prevention (P2) to interactively shaping the ethics related to the learning process between humans and the AI system (P3)
  • Facilitate a new distributed, incremental collaborative learning method by going beyond the dominant off-line and centralized data processing approach (P4)

Entries:
Signage system for the navigation of autonomous robots in indoor environments
IEEE Transactions on Industrial Informatics. num. 1 , vol. 10 , pages: 680 – 688 , 2014
A. Corrales M. Malfaz M.A. Salichs
An autonomous social robot in fear
IEEE Transactions on Autonomous Mental Development. num. 2 , vol. 5 , pages: 135 – 151 , 2013
A. Castro-Gonzalez M. Malfaz M.A. Salichs
Fast 3D Cluster-tracking for a Mobile Robot using 2D Techniques on Depth Images
Cybernetics and Systems: An International Journal. num. 4 , vol. 44 , pages: 325 – 350 , 2013
A. Ramey M. Malfaz M.A. Salichs
A new approach to modelling emotions and their use on a decision making system for artificial agent
IEEE Transactions on Affective Computing . num. 1 , vol. 3 , pages: 56 – 68 , 2012
M. Malfaz M.A. Salichs
A biologically inspired architecture for an autonomous and social robot
IEEE Transactions on Autonomous Mental Development. num. 3 , vol. 3 , pages: 232 – 246 , 2011
M. Malfaz A. Castro-Gonzalez R. Barber M.A. Salichs
Integration of a voice recognition system in a social robot
Cybernetics and Systems: An International Journal (Online). num. 4 , vol. 42 , pages: 215 – 245 , 2011
F. Alonso M.A. Salichs
Maggie: A Social Robot as a Gaming Platform
International Journal of Social Robotics. num. 4 , vol. 3 , pages: 371 – 381 , 2011
A. Ramey V. Gonzalez Pacheco F. Alonso A. Castro-Gonzalez M.A. Salichs
Learning to avoid risky actions
Cybernetics and Systems: An International Journal. . num. 8 , vol. 42 , pages: 636 – 658 , 2011
M. Malfaz M.A. Salichs
Toma de Decisiones en Robótica
Revista Iberoamericana de Automática e Informática industrial (RIAI). num. 4 , vol. 7 , pages: 5 – 16 , 2010
M.A. Salichs M. Malfaz Javi F. Gorostiza

Entries:
Robot self-preservation and adaptation to user preferences in game play, a preliminary study
IEEE International Conference on Robotics and Biomimetics (IEEE-ROBIO 2011), 2011, Phuket Island, Thailand
A. Castro-Gonzalez M. Malfaz M.A. Salichs
Playzones : A robust detector of game boards for playing visual games with robots
Robot 2011 – III Workshop de Robótica : Robótica Experimental, Sevilla, Spain
A. Ramey M.A. Salichs
Selection of Actions for an Autonomous Social Robot
International Conference on Social Robotics. Best Student Paper Finalist (http://dx.doi.org/10.1007/978-3-642-17248-9_12), 2010, Singapore, Singapore
A. Castro-Gonzalez M. Malfaz M.A. Salichs
Using a Social Robot as a Gaming Platform
International Conference on Social Robotics 2010, 2011, Singapore, Singapore
A. Ramey V. Gonzalez Pacheco F. Alonso A. Castro-Gonzalez M.A. Salichs
Infrared Remote Control with a Social Robot
FIRA RoboWorld Congress 2009. International Conference on Social Robotics (http://dx.doi.org/10.1007/978-3-642-03986-7_10), 2009, Incheon, Korea
A. Castro-Gonzalez M.A. Salichs
Learning to deal with objects
ICDL09: The 8th International Conference on Development and Learning , Shanghai, China
M. Malfaz M.A. Salichs

Previous Project

next project